General purpose · EVST range
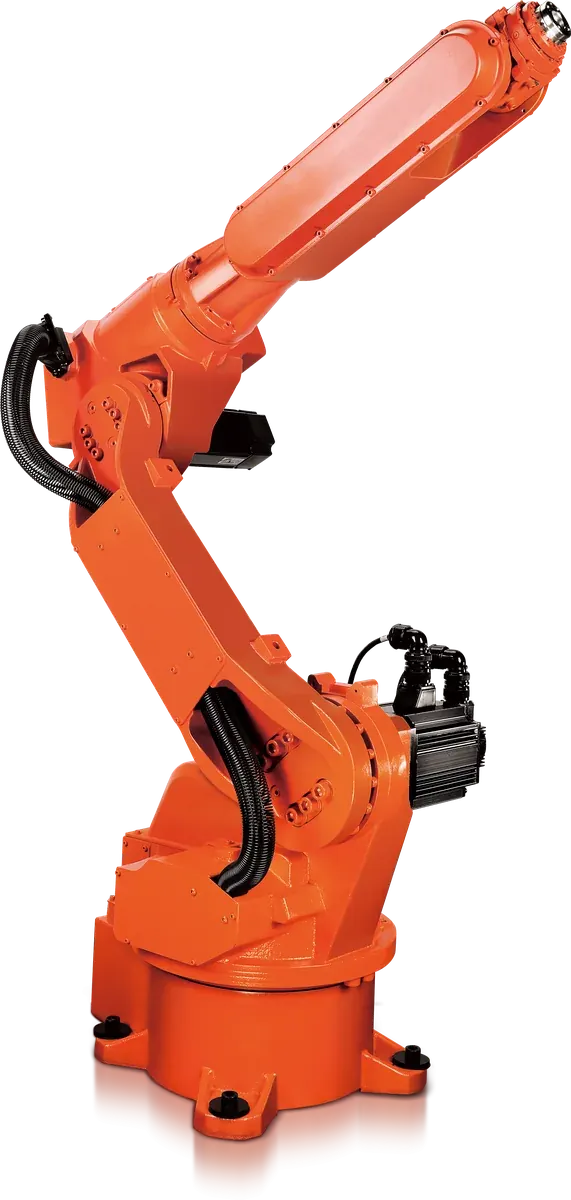
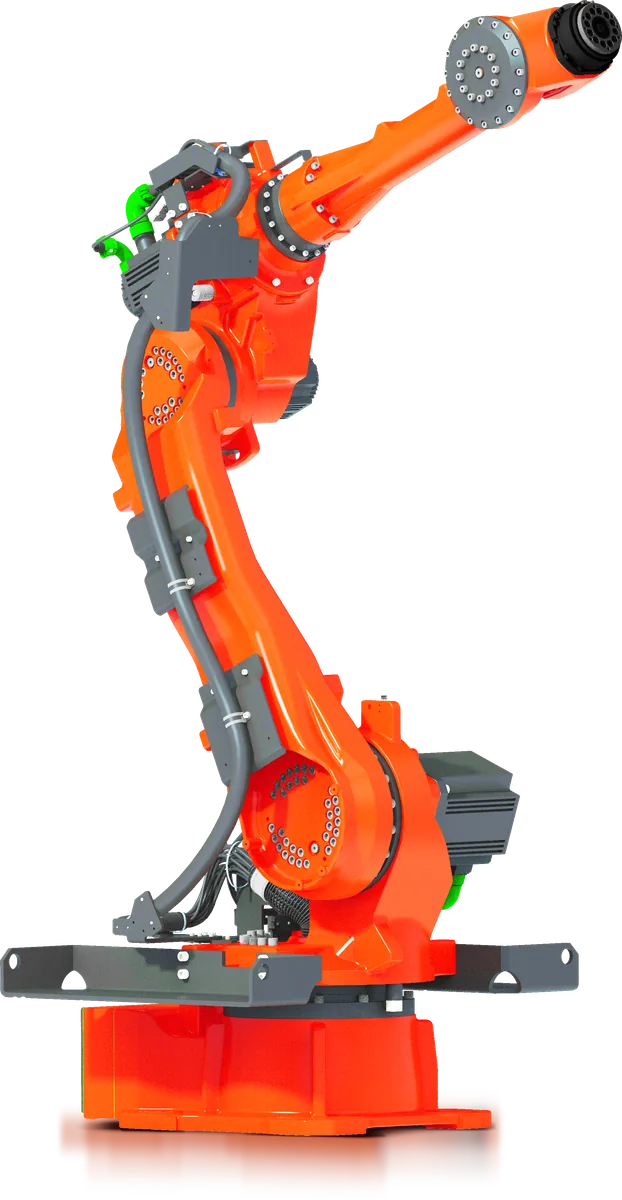
EVST G10-2000 10 kg general-purpose robot
The EVST G10-2000 is a 6-axis EVST industrial robot for general-purpose use, with 10 kg of wrist payload and 2,001 mm of maximum reach.
| Payload | 10 kg |
|---|---|
| Reach | 2,001 mm |
| Axes | 6 |
| Repeatability | ±0.05 mm |
| Mass | 275 kg |
Technical description
About the EVST G10-2000
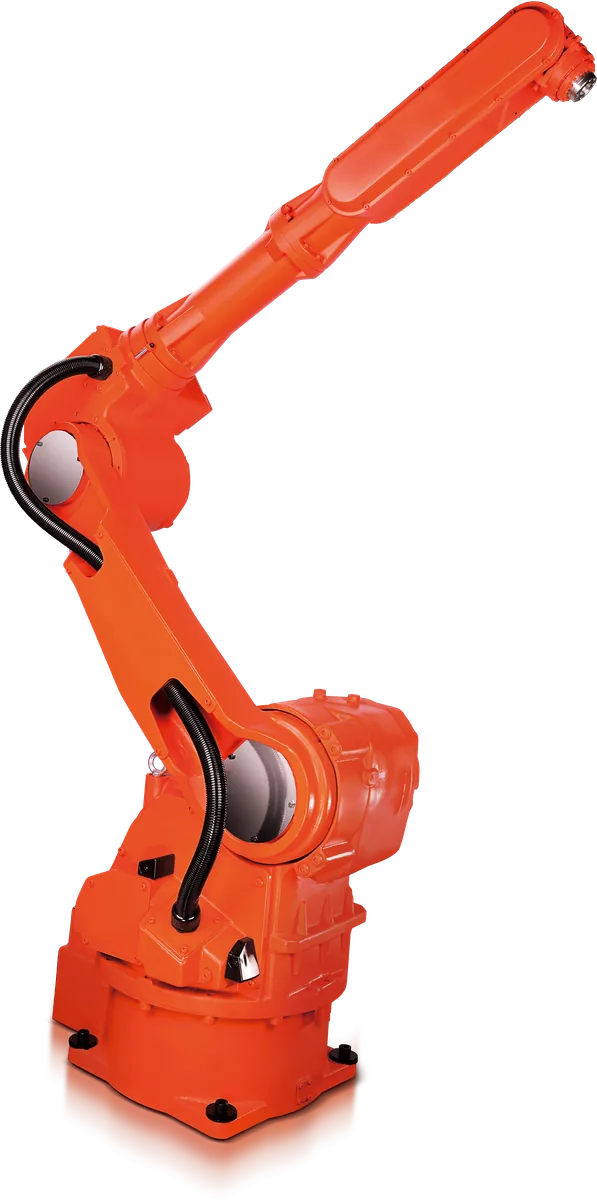
The EVST G10-2000 is a 6-axis EVST industrial robot for general-purpose use, with 10 kg of wrist payload and 2,001 mm of maximum reach.
The structure is highly compact and mounting is flexible. The robot has a large workspace, high speed and high repeatability, for welding, spraying, loading and unloading, handling, sorting, assembly and other applications.
Configurations and options are defined in each cell design.
Official datasheet
- Mounting
- On the floor or on a wall
Maximum speed per axis
- J1
- 154 °/s
- J2
- 154 °/s
- J3
- 171 °/s
- J4
- 401 °/s
- J5
- 515 °/s
- J6
- 658 °/s
Applications
Typical EVST G10-2000 applications
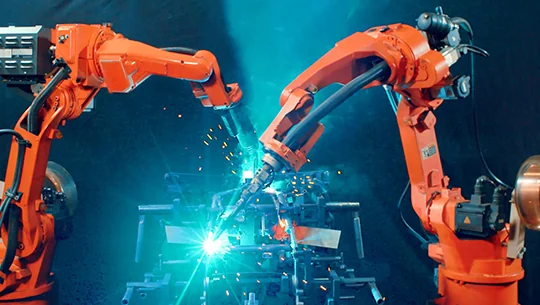
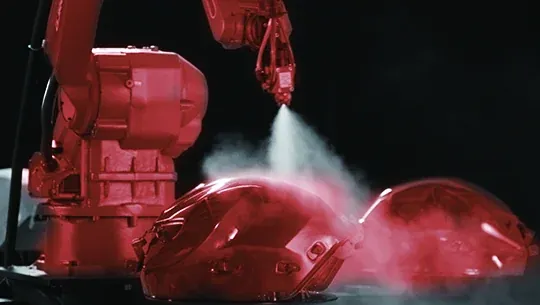
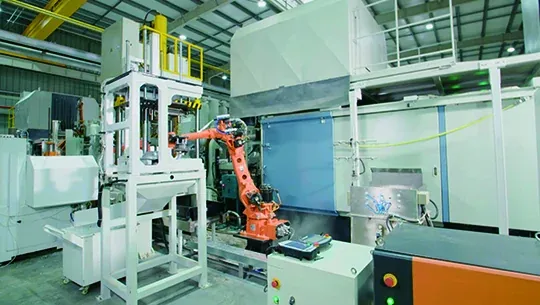
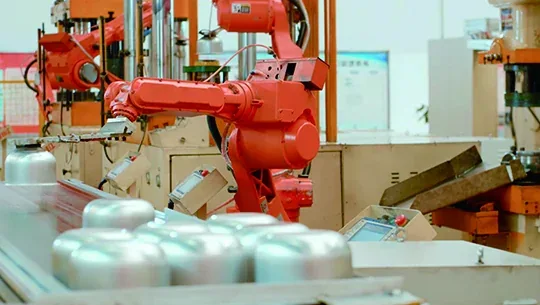
Processes recommended for the EVST G10-2000. The photos show installations with EVST robots and illustrate the process, not this specific model.
FAQ
EVST G10-2000 frequently asked questions
Answers based on the official datasheet.
What is the payload of the EVST G10-2000?
The wrist payload of the EVST G10-2000 is 10 kg.
What is the reach of the EVST G10-2000?
The maximum reach of the EVST G10-2000 is 2,001 mm.
How many axes does the EVST G10-2000 have?
The EVST G10-2000 is a 6-axis robot.
What is the repeatability of the EVST G10-2000?
The positioning repeatability of the EVST G10-2000 is ±0.05 mm.
How much does the EVST G10-2000 weigh?
The robot mass is 275 kg.
Which applications is the EVST G10-2000 suited to?
The EVST G10-2000 covers welding, spraying, loading and unloading, handling, sorting and assembly.
How is the EVST G10-2000 mounted?
It is mounted on the floor or on a wall.
Related models
More robots from the EVST range
Contact
Send us the process, the part and the target cycle time.
BR Robotics replies with the recommended model, the cell layout and the quote.